
Featured Project
PUSHPAK GCS
Ground Control Station
A next-generation Ground Control Station for drones and robotic systems. PUSHPAK GCS is more than just a flight controller — it's the command center of the entire PUSHPAK ecosystem.
Status
In Development
Role
Sole Developer
Category
Robotics / UAV Software
Platform
Desktop (Cross-platform)
Related
Companion, Drone Platform
Overview
PUSHPAK GCS is a cross-platform mission management and monitoring software designed for drones and autonomous robotic systems. It provides real-time telemetry, mission planning, device management, plugin ecosystem, and seamless integration with PUSHPAK Companion.
Modular Architecture
Designed from the ground up to support custom plugins and third-party robotic applications without modifying core code.
Real-Time Telemetry
Processes high-frequency MAVLink data streams seamlessly using a lightweight UI thread architecture.
Unified Ecosystem
Directly interfaces with PUSHPAK Companion for seamless device discovery, health monitoring, and service management.
System Architecture
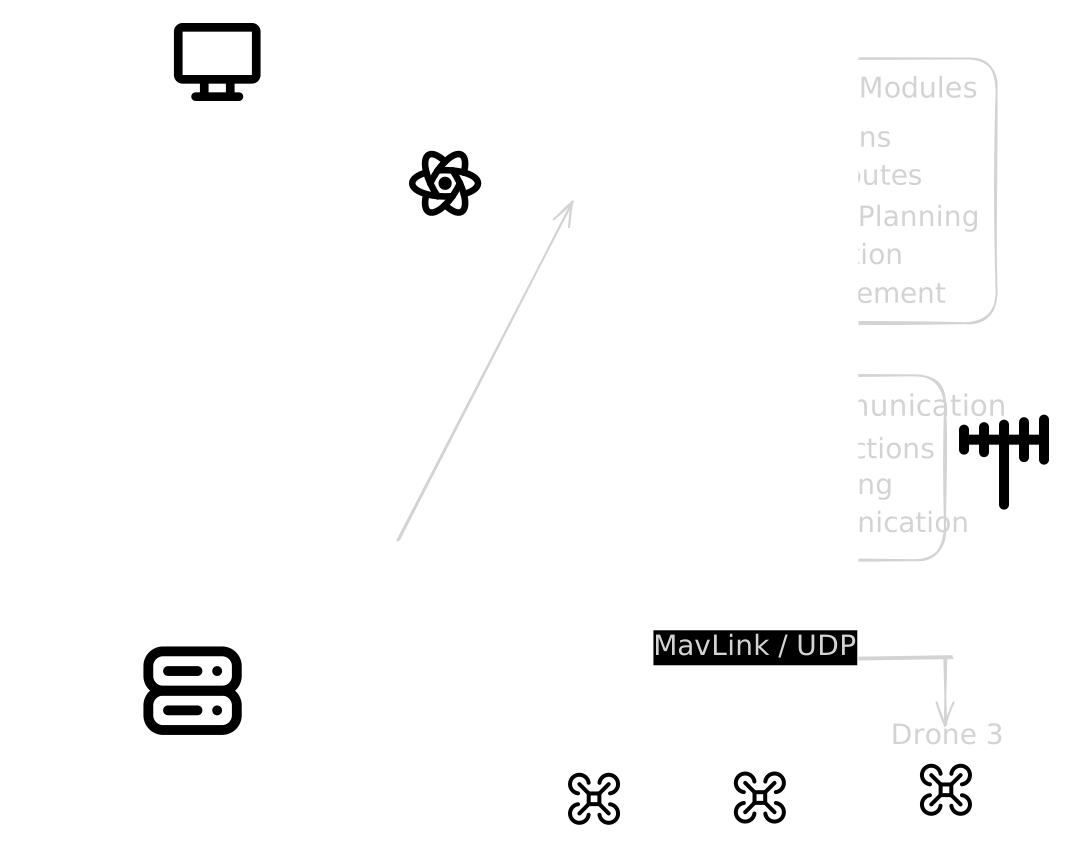
Screenshots & UI Showcase
Visual walk-through of application workflows


Tech Stack
Technical Overview
Utilizes Electron to package the web application into a high-performance cross-platform desktop shell.
Powers the dynamic and highly interactive user interface with instantaneous React state updates.
Provides end-to-end TypeScript safety across complex robotic data structures and IPC channels.
Parses and serializes drone telemetry efficiently using the MAVLink protocol via WebSockets.
Roadmap
Multi-vehicle support
Q2 2024AI Copilot & Natural Language Interface
Q3 20243D Map Visualization & Simulation
Q4 2024Cloud Sync & Team Collaboration
Q1 2025Companion Marketplace Integration
Q2 2025Gallery
⭐ More Than Just a GCS
PUSHPAK GCS is built to be the central operations platform of the entire PUSHPAK ecosystem — unifying mission control, onboard application management, and AI-powered robotics workflows.