Robotics Runtime Platform
PUSHPAK Companion
Modular Onboard Computing Platform
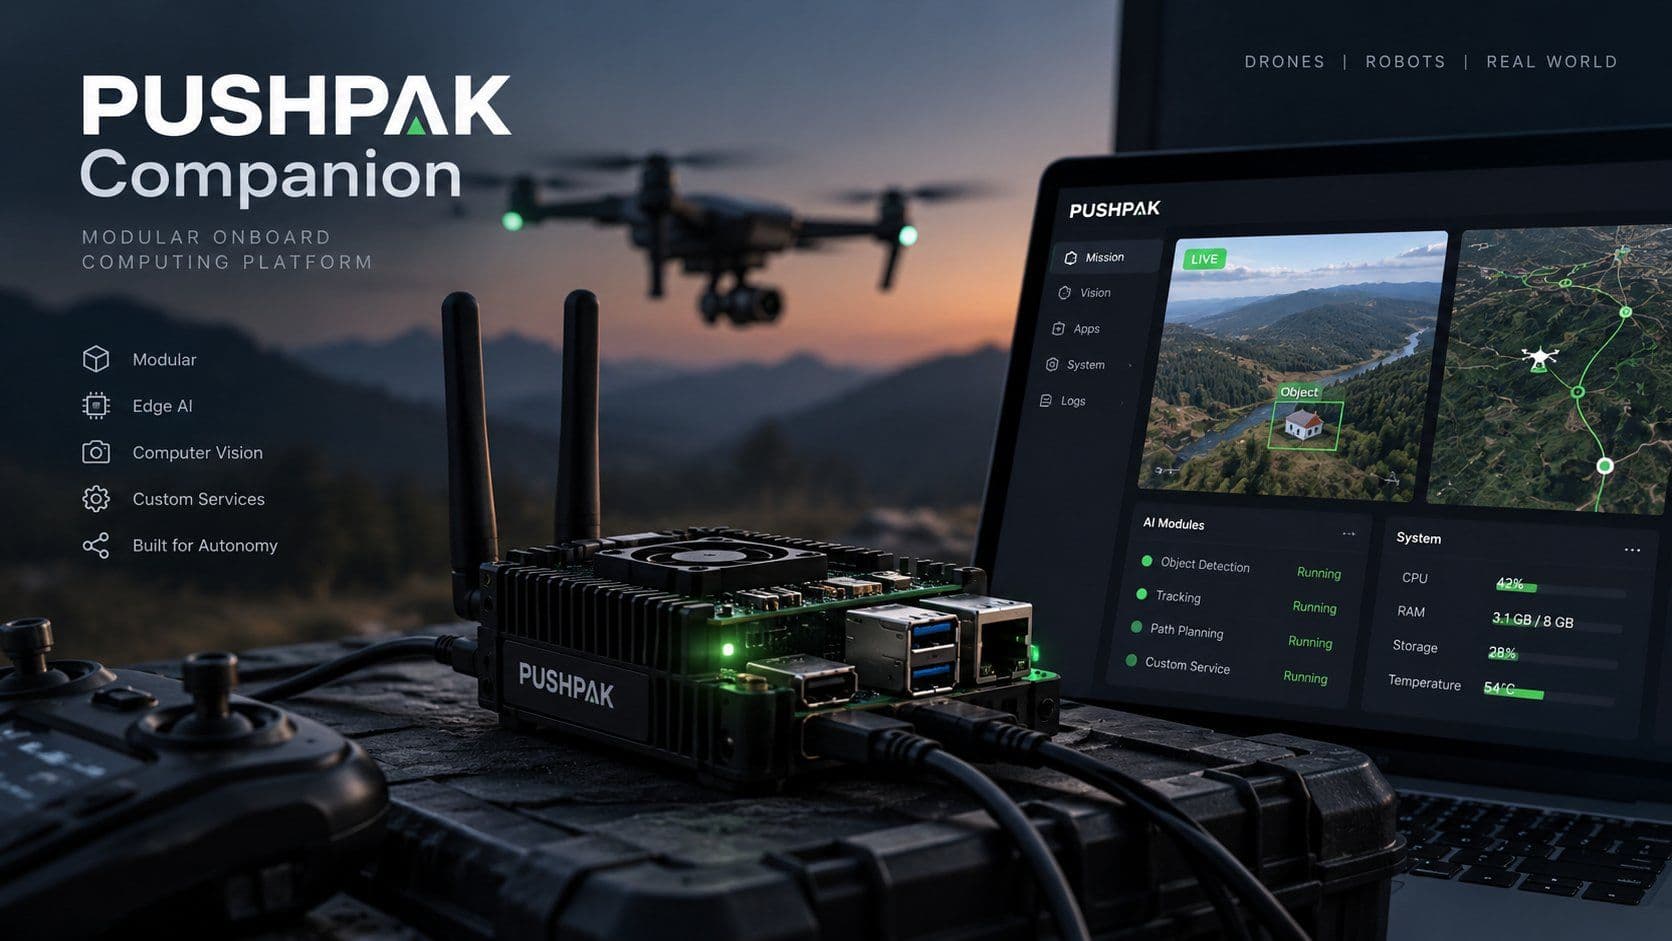
A modular onboard computing platform designed for drones, robots, and autonomous systems. It transforms a companion computer such as a Raspberry Pi into an extensible runtime capable of hosting multiple applications, AI workloads, computer vision pipelines, and custom services.
Status
In Development
Role
Sole Developer
Category
Embedded Systems / Robotics
Platform
Raspberry Pi, Linux SBCs
Related
PUSHPAK GCS, PushBook SDK
Overview
Unlike traditional companion computer software, PUSHPAK Companion is designed as an operating platform rather than a single application. It enables developers to build, deploy, and manage independent onboard applications without modifying the core runtime, creating a scalable ecosystem for robotics development.
Modular Runtime
Applications run independently from the core runtime, allowing new functionality to be added without changing the platform itself.
Plugin SDK
Developers can build onboard applications using a standardized SDK while remaining isolated from the Companion's internal implementation.
Service Management
The runtime manages application startup, shutdown, health monitoring, and lifecycle management automatically.
Hardware Abstraction
Applications interact with standardized interfaces instead of directly accessing hardware, improving portability across devices.
System Architecture

Tech Stack
Technical Overview
Designed as an operating platform rather than a single application, allowing developers to build and manage independent onboard apps without modifying the core runtime.
Addresses limitations of tightly coupled existing solutions by providing a standardized SDK for third-party extensions and a lifecycle manager.
Supports seamless communication with PUSHPAK GCS, exposing a consistent interface to external control systems and abstracting complex hardware calls.
Prepares the platform for autonomous robotics workflows, edge AI models, and computer vision integration via a layered runtime architecture.
Roadmap
Application Marketplace & Remote Deployment
PlannedOTA Updates & Containerized Applications
PlannedAI Copilot & Edge AI Model Management
PlannedCloud Integration & Fleet Synchronization
PlannedGallery
⭐ Lessons Learned
Developing PUSHPAK Companion significantly improved my understanding of systems architecture, runtime design, and software extensibility. Rather than building a single robotics application, I learned how to design a reusable platform capable of supporting an entire ecosystem of onboard services.